


Download
latest Releases : 2.0.0-RELESE
| 2.1.0-RELESE | Download page |
| 2.0.1-RELESE | Download page |
Number of Projects
| RT-Component | 154.5 |
| RT-Middleware | 35 |
| Tools | 25 |
| Documentation | 2 |
Choreonoid
Motion editor/Dynamics simulator
OpenHRP3
Dynamics simulator
OpenRTP
Integrated Development Platform
AIST RTC collection
RT-Components collection by AIST
TORK
Tokyo Opensource Robotics Association
DAQ-Middleware
Middleware for DAQ (Data Aquisition) by KEK
Aldebaran Robotics Humanoid NAO
RT-Component for controlling a humanoid robot "NAO" (by aldebaran robotics).
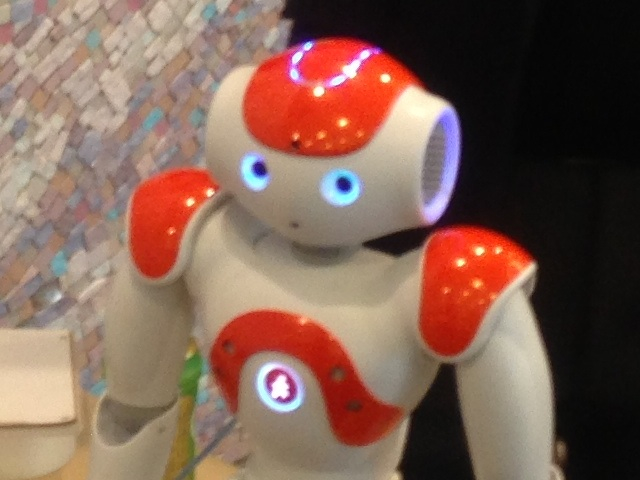
This component allows you :
1. TextToSpeech
2. Motion (Direct Motor Control and Walk)
3. Memory (Sensory data aquisition)
4. Audio
5. Vision
6. Speech Recognition
Launguage : Python
Operating System : Mac, Win, Linux
Depends : pynaoqi 1.14.5, OpenRTM-aist 1.1 Python version.
Still in implementation. Please check this component's official website in Ogata Laboratory's website.